projects
Applied robotics and engineering systems — perception, localisation, navigation and control stacks built and deployed on real platforms.
MLOps Pipeline for 3D Scene Reconstruction
Built an automated end-to-end MLOps pipeline orchestrating distributed 3D reconstruction and dense point cloud generation. Containerized multi-stage Structure-from-Motion workflows using Docker, integrating automated data versioning, experiment tracking, and artifact pipelines for reproducible multi-node deployment.
Team Abhiyaan — IIT Madras
The two systems below were built within Team Abhiyaan, IIT Madras' autonomous ground vehicle team, rather than as independent academic projects.
- Led a 30+ member autonomous robotics team.
- Oversaw software architecture, development, integration and validation.
- Worked across perception, localisation, navigation and control.
- Developed autonomous platforms for international competition and campus deployment.
- Secured 7th overall among 30+ international teams and 6th in the Design Challenge at IGVC 2024.
BOLT — Driverless Institute Shuttle
Designed and field-deployed a full ROS autonomy stack converting an electric golf cart into a driverless campus shuttle. Integrated a 3D LiDAR–camera fusion perception pipeline achieving 98.3% classification accuracy, comprehensively validated in CARLA and Gazebo before physical deployment.
Vidyut — IGVC 2024 Autonomous Vehicle
Led software development and systems integration for Team Abhiyaan's autonomous ground vehicle at IGVC 2024 in Michigan. Built a ROS2 navigation stack featuring Nav2, ORB-SLAM3, SLAM Toolbox, and CUDA-accelerated vision, placing 6th in the Design Challenge and 7th overall internationally.
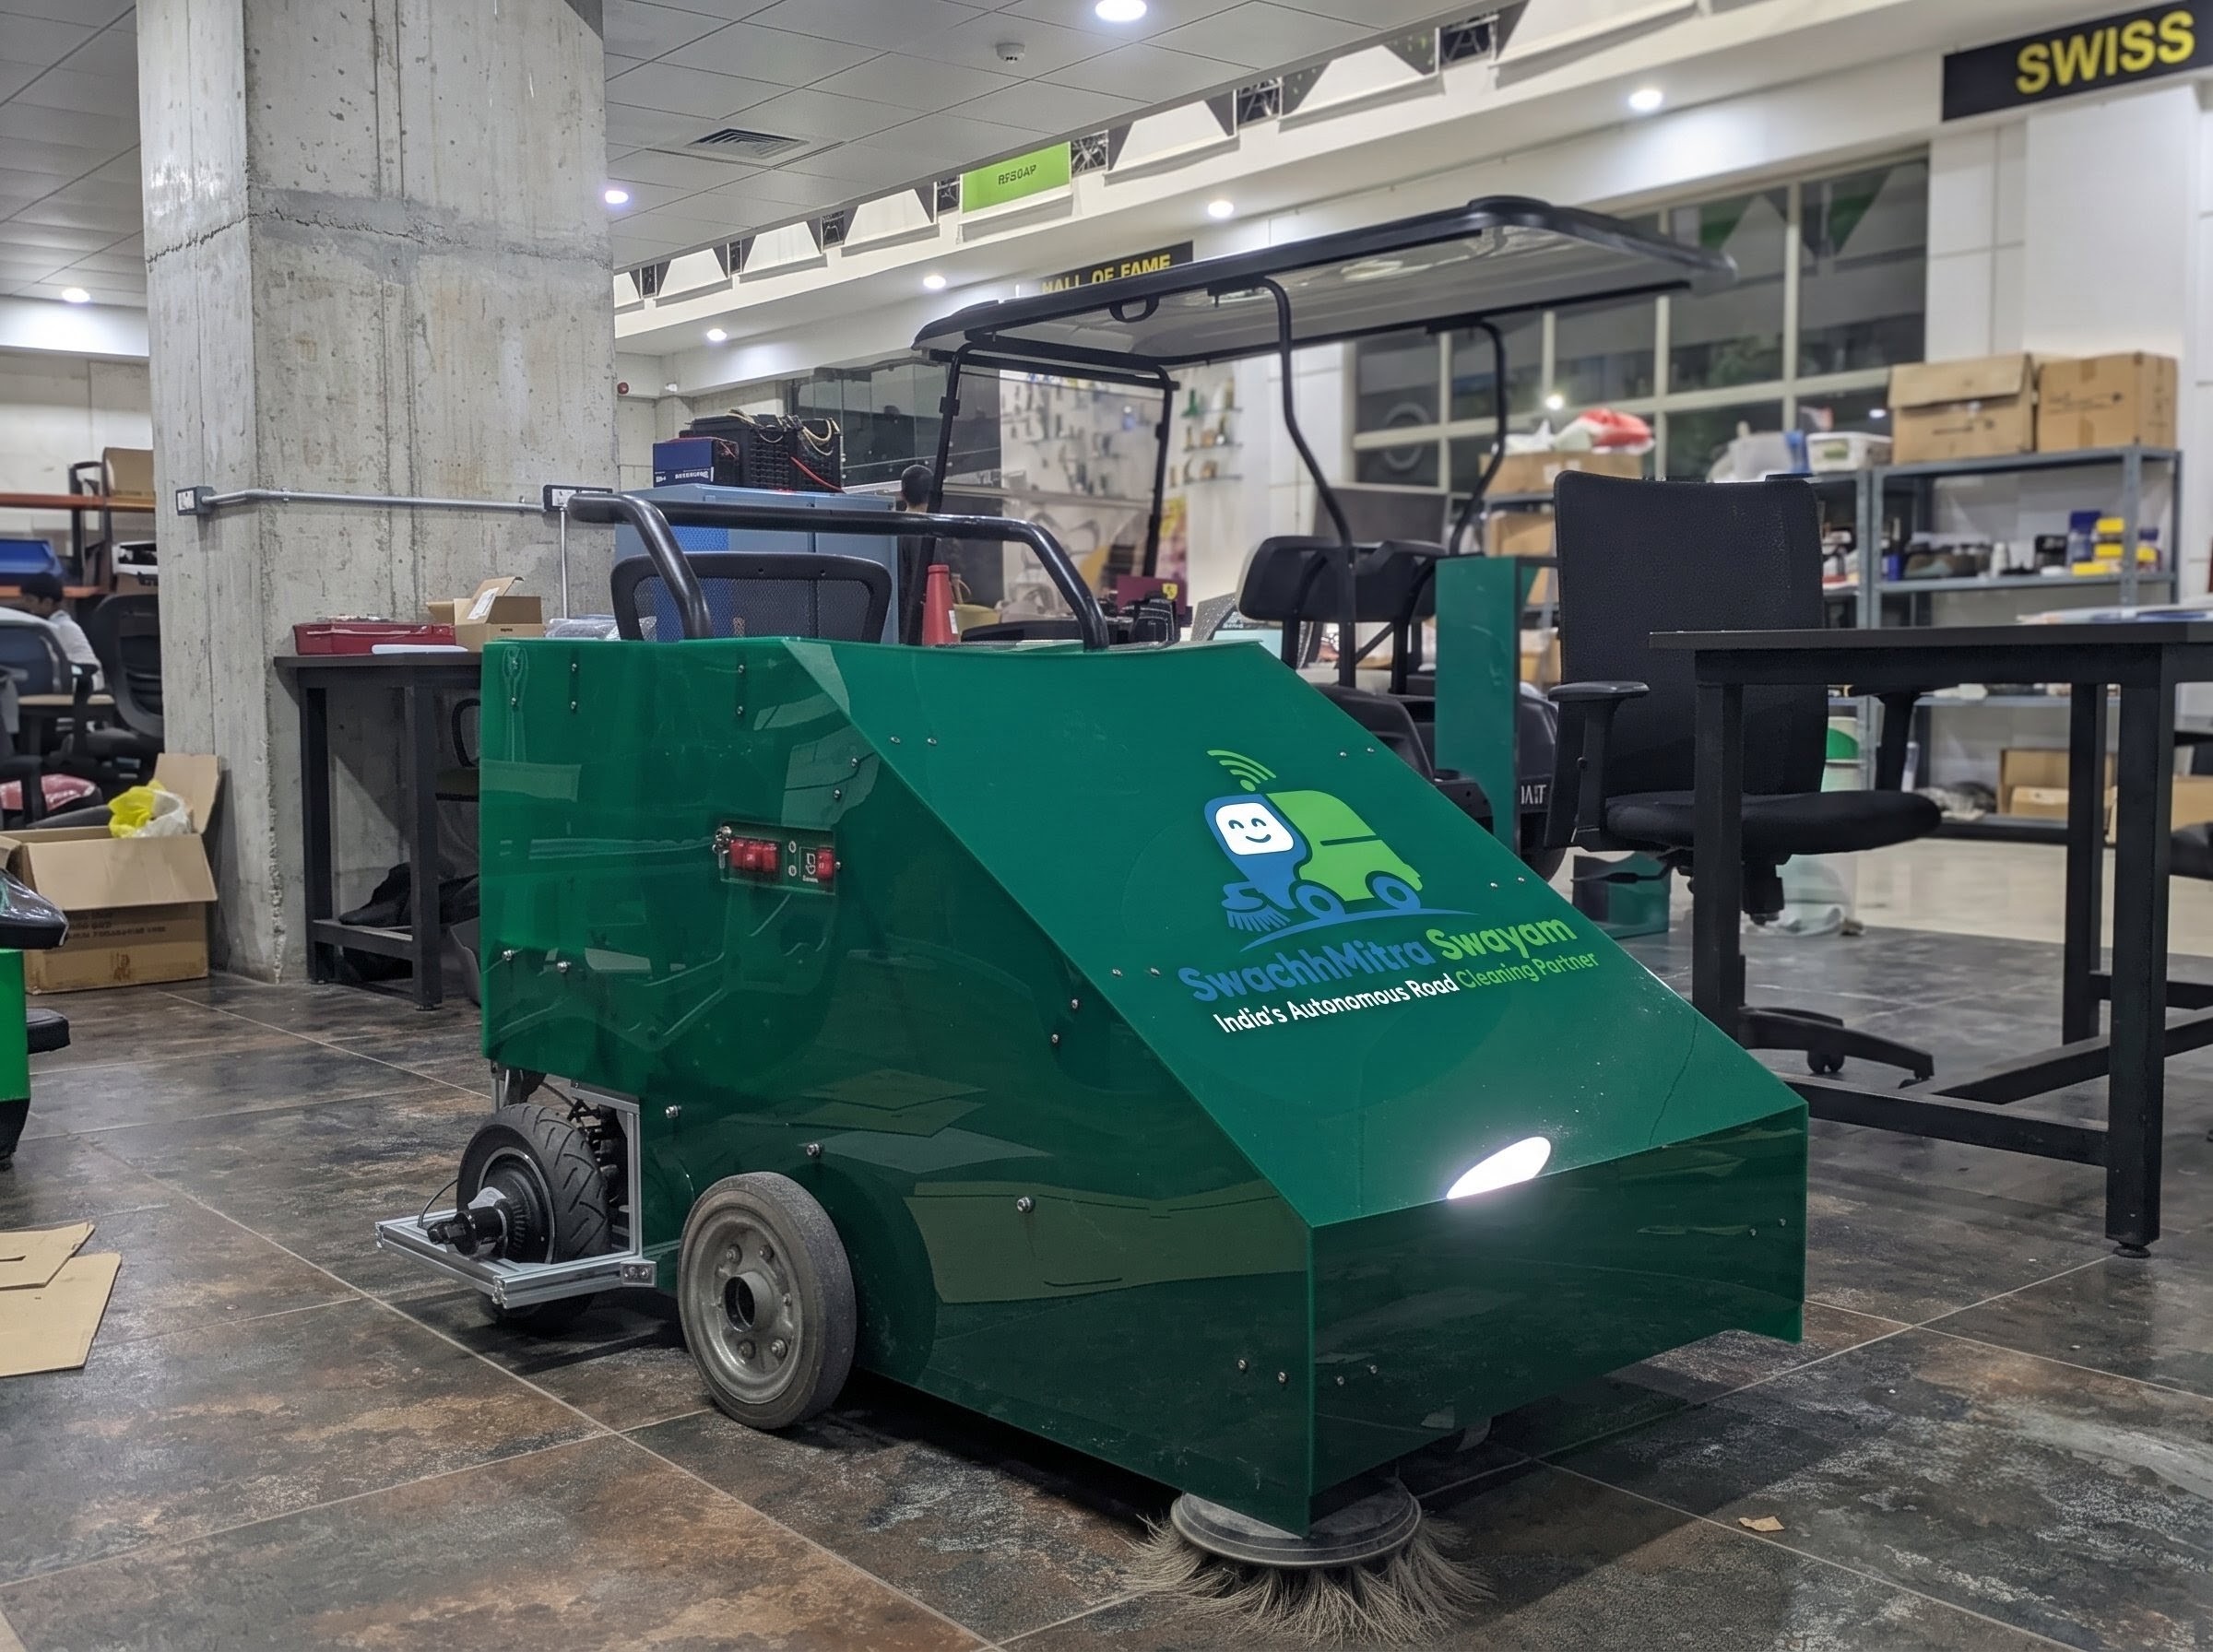
Autonomous Road Dust Collector
Developed an autonomous road dust collection robot for unmanned operation in suburban environments. Engineered the navigation stack using FAST-LIO2 for 3D LiDAR odometry and mapping, NDT-based localization for pose estimation, and Lanelet semantic maps for context-aware path planning.
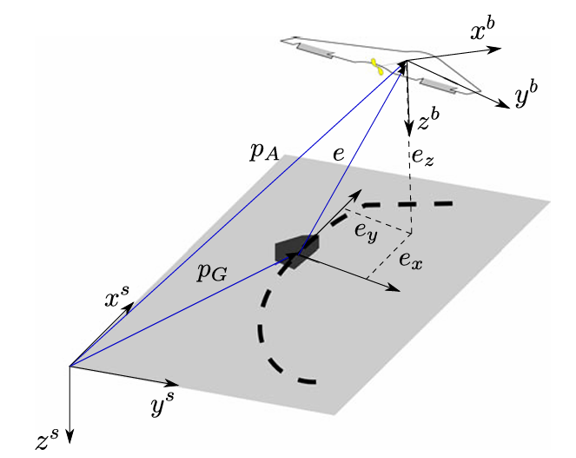
Optimal Rendezvous Trajectory for Unmanned Aerial-Ground Vehicles
Formulated an optimal control framework for autonomous UAV–UGV rendezvous and in-motion docking under nonlinear dynamics. Designed an aggressiveness-index-based trajectory tracking strategy in PRONTO, providing tunable rendezvous behaviors with verified numerical convergence.